Towards Reinforcement Learning from Neural Feedback: Mapping fNIRS Signals to Agent Performance
Santaniello, J., Russell, M., Jiang, B., Sassaroli, D., Jacob, R., Sinapov, J., In Proceedings of the AAAI Conference on Artificial Intelligence, Singapore, 2026

Contrastive Auditory Knowledge Transfer for Tool-Mediated Robot Interaction with Granular Objects
Liu, S., Huang, J., Huan, Z., Hughes, M. C., Sinapov, J. (2026) In Proceedings of the 2026 IEEE International Conference on Robotics and Automation (ICRA), Vienna, Austria.

Tool-Mediated Robot Perception of Granular Substances Using Multiple Sensory Modalities
Liu, S., Sinapov, J. (2025) In Proceedings of the 2025 IEEE International Conference on Robotics and Automation (ICRA)

FLEX: A Framework for Learning Robot-Agnostic Force-based Skills Involving Sustained Contact Object Manipulation
Fang, S., Gao, W., Goel, S., Thierauf, C., Scheutz, M., Sinapov, J. (2025) In IEEE International Conference on Robotics and Automation (ICRA)

OnAIR: Applications of the NASA on‐board artificial intelligence research platform.
Gizzi, Evana, et al. (2025) AI Magazine 46.3

Transferring Implicit Knowledge of Non-Visual Object Properties Across Heterogeneous Robot Morphologies
Tatiya, G., Francis, J., and Sinapov, J. (2023) in proceedings of the IEEE International Conference on Robotics and Automation (ICRA), 2023.

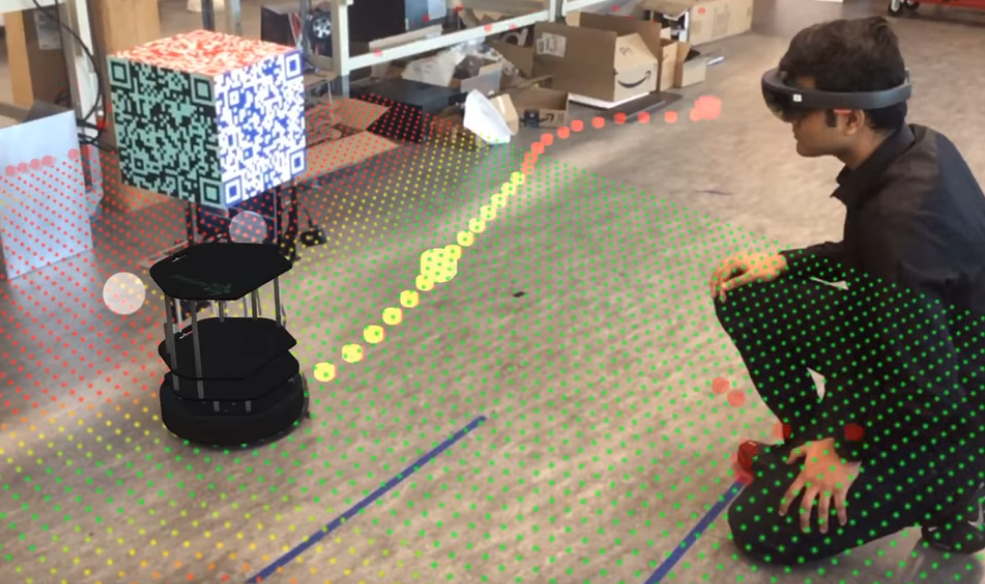
First Encounters with a Robot: The Value of Augmented Reality when Learning about Mobile Robots
Cleaver, A., Chen, V., and Sinapov, J. (2023) In proceedings of the 6th International Workshop on Virtual, Augmented, and Mixed Reality for Human-Robot Interactions (VAM-HRI), 2023

Creative Problem Solving in Artificially Intelligent Agents:A Survey and Framework
Gizzi, E., Nair, L., Chernova, S., and Sinapov, J. (2022) Journal of Artificial Intelligence Research 75 (2022)